DeveloperIntegrator
Experimental
Experimental · documentation-first
Mobile platform hardware
Maintained CAD, production files, wiring, BOMs, component data and safety notes for the differential-drive base.
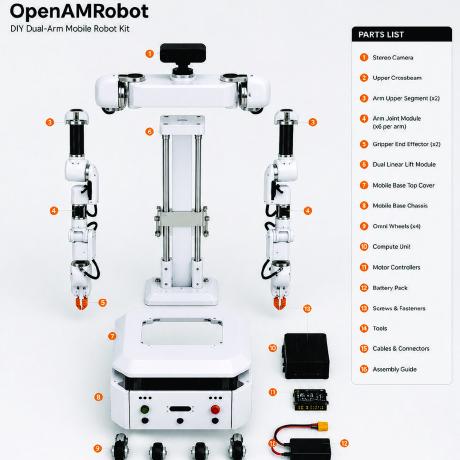
openamr-platform-hw is the canonical source for the physical mobile base.
| Subsystem | Current reference configuration |
|---|---|
| Compute | Raspberry Pi 5, 8 GB, Ubuntu Server 24.04 and ROS 2 Jazzy |
| Microcontroller | Teensy 4.0; 3.3 V I/O and not 5 V tolerant |
| Drive | Two 24 V, 60 W BLDC geared motors with ZBLD drivers |
| Feedback | AS5040 wheel encoders and MPU6500 IMU |
| Perception | RPLIDAR A1, legacy (existing robot), and Raspberry Pi Camera Module 3 NoIR; the OpenAMRobot 2.0 LiDAR is the RPLIDAR S3 |
| Geometry | 0.20 m wheel diameter and 0.46 m measured track |
The repository contains real mechanical CAD, per-part production files, electrical and mechanical BOMs, wiring/pinout documentation, datasheets and safety material. It also documents critical current limitations: no battery fuse, no battery-side disconnect/hardware E-stop, and no active Raspberry Pi 5 cooling in the reference build.
Electrical boundary
Teensy 4.0 inputs are not 5 V tolerant, and the documented AS5040 encoders must use the 3.3 V rail. Verify the owning repository before wiring or powering hardware.