Find the owning source
Architecture, repositories, interfaces and subsystem references for people integrating or extending the platform.
Reference map
System architecture
Subsystem boundaries, delivery layers and how the platform fits together.
Repository ecosystem
The canonical source for every software, firmware, hardware and shared component.
Mobile platform
Navigation, docking, bring-up, embedded control, CAD and electronics.
Upper body
Lift, robot arms, manipulation architecture and developing integrations.
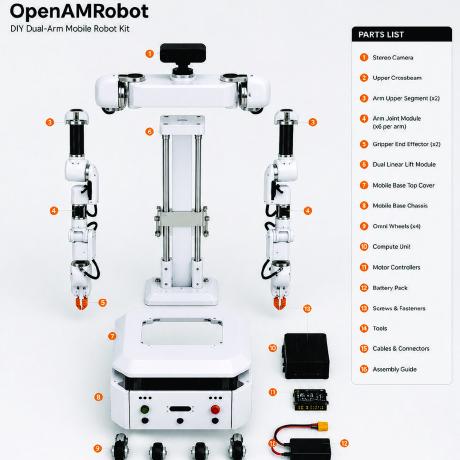
OpenAMRobot 2.0 design
Hardware architecture, general arrangement and stability model of the robot being designed in development cycle 2.
Reference use cases
The platform applied to concrete workflows: the OpenAMRobot 2.0 reference use case and, for 3.0, dark-store picking.
Interfaces
Messages, services, actions and stable contracts between components.
Communication
APIs, middleware, telemetry and external integration boundaries.
Canonical-source rule
The owning repository is canonical for exact versions, parameters, schemas and contracts. This knowledge hub teaches what they mean, how they fit together and how to choose, apply and verify them in a complete robot.