BuilderIntegrator
Experimental
Experimental build path
Build a platform you can verify
Move from workspace and parts to assembly, software, calibration and a recorded acceptance baseline.
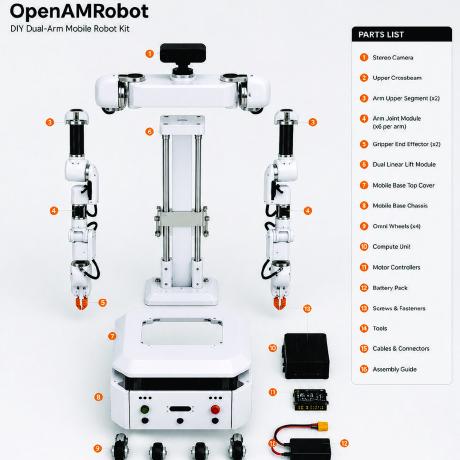
Build sequence
Prepare→Source→Assemble→Install→Bring up→Calibrate→Accept
| Stage | Outcome | Start here |
|---|---|---|
| Prepare | Safe workspace, tools, skills and realistic plan | Before you start |
| Source | BOM and revision-matched parts are available | The kit |
| Assemble | Mechanics, electronics and wiring match the design source | Assembly |
| Install | Firmware and ROS 2 software are installed and identified | Getting software onto the robot |
| Bring up | Power, motors, sensors and first motion pass controlled checks | Bring-up |
| Calibrate | Odometry and sensor geometry have recorded baselines | Calibration |
| Accept | The configuration passes measurable acceptance tests | Acceptance |
The canonical CAD, BOM and manufacturing source is in openamr-platform-hw. Embedded control belongs to openamr-platform-fw, and ROS 2 integration belongs to openamr-platform-sw.
Current maturity
The released source is suitable for study and development. Simulation, Nav2 and docking run end to end; real-robot drivers, control and hardware acceptance documentation remain in progress. Do not treat an unfinished page as a validated safety or manufacturing instruction.