DeveloperIntegrator
Experimental
Mixed maturity
Extend the platform through owned contracts
Add devices, code, firmware, hardware, simulations or policies without duplicating another repository's responsibility.
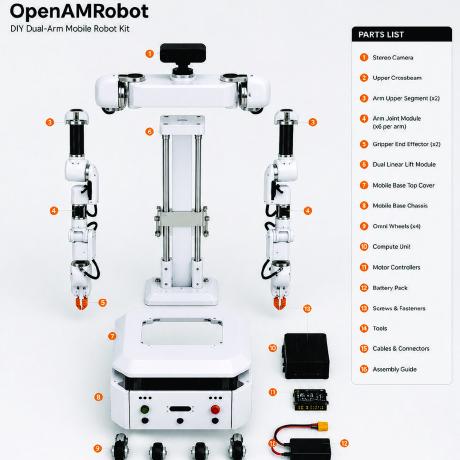
Choose the owning layer
| Extension | Owning source | Start here |
|---|---|---|
| ROS 2 behaviour and platform integration | openamr-platform-sw |
Software |
| Embedded control and bridges | openamr-platform-fw |
Firmware |
| Chassis, power and electronics | openamr-platform-hw |
Hardware |
| Shared messages, services and actions | openamrobot-interfaces |
Working with interfaces |
| UI panels and Blockly blocks | openamrobot-ui |
Extending the UI |
| Reusable arms and devices | openamrobot-manipulation |
Device packages |
| Worlds and scenario validation | Owning software repository | Simulation |
| Datasets and policies | Developing manipulation/AI layer | AI and policies |
Choose contract→Check maturity→Implement→Test→Document→Contribute
The mobile simulation, navigation and docking stack is active but experimental. The shared manipulation framework and upper-body repositories are planned for the v0.2 cycle and simulation-first; their current contracts are design direction, not released implementation.
Use the repository map before changing a contract and follow the contribution workflow for DCO, contributor agreement, review and testing requirements.