BeginnerBuilder
Stable
Core concepts
Understand the robot before changing it
Build the mental model needed to work safely with the mobile base, navigation, manipulation, ROS 2 and Embodied AI.
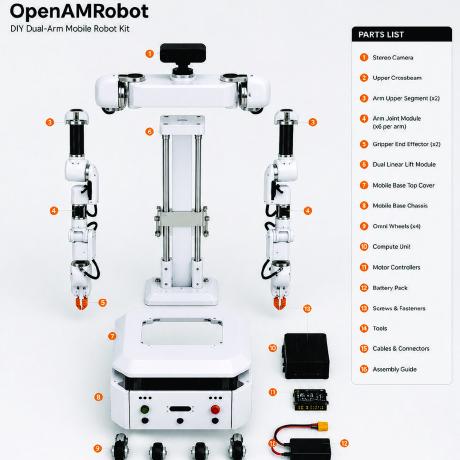
What you will understand
| Area | Why it matters | Continue with |
|---|---|---|
| Robot anatomy | Connect mechanics, power, compute, sensors and actuators to observable behaviour | Robot anatomy |
| Navigation | Understand frames, odometry, SLAM, localization, planning and docking | How navigation works |
| Manipulation | Understand reach, kinematics, planning, grippers and the lift | How manipulation works |
| Embodied AI | See how demonstrations become datasets, policies and evaluated behaviour | Teaching by demonstration |
| ROS 2 | Read nodes, topics, actions, parameters, TF and launch composition | ROS 2 in an afternoon |
| Safety | Recognize operating limits, stop conditions and required supervision | Working safely |
Recommended order
Anatomy→Safety→ROS 2→Navigation→Manipulation→Embodied AI
You do not need every topic before starting. A Domain Expert can begin with safety and operation; a Builder should add anatomy and power; a Developer should complete the ROS 2 and interface material.
Capability boundary
Foundations explains system concepts. Exact versions, parameters and interfaces remain in the repository that owns them; the current mobile software stack is experimental, and upper-body/manipulation implementation is planned and simulation-first.