DeveloperIntegrator
Experimental
Experimental
Shared interface contracts
One source for reusable ROS 2 messages, services, actions and cross-repository schemas.
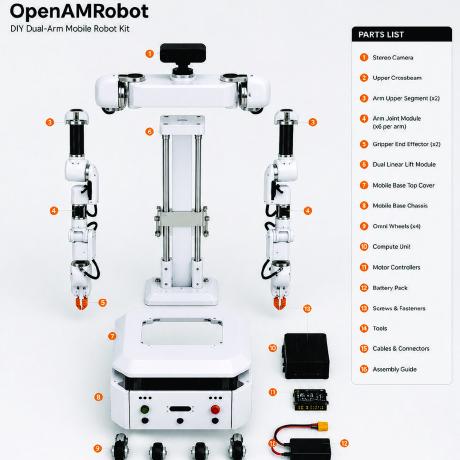
openamrobot-interfaces separates shared contracts from application logic so the platform software, UI, simulation and future integrations do not redefine the same interface.
| Belongs here | Belongs elsewhere |
|---|---|
| Shared ROS 2 messages, services and actions | Navigation, docking or application behaviour |
| Reusable JSON/YAML schemas | Hardware drivers and embedded implementation |
| Versioning and interoperability rules | UI components and presentation logic |
| Transport-independent contracts where practical | Middleware bridges and deployment configuration |
Consumers should depend on the shared package and treat incompatible contract changes as versioned migrations. Concrete behaviour remains in the repository that implements it.