Stable
Find the shortest path to your goal
Choose an outcome first; learn only the detail you need.
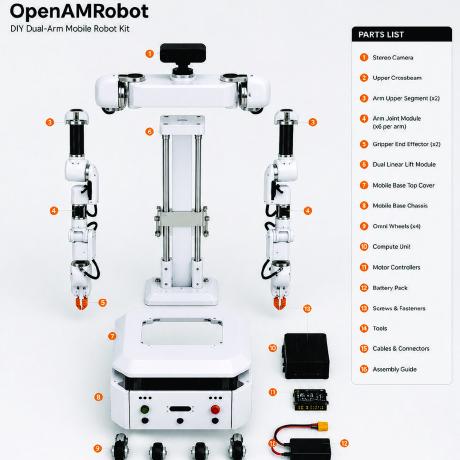
What OpenAMRobot is
OpenAMRobot is an open-source robotics ecosystem operated by Botshare LTD. It combines a modular mobile platform, ROS 2 software, embedded firmware, open hardware, shared interfaces, an operator UI and a developing manipulation and Embodied AI layer.
Its operating idea is simple: the person who understands the work should be able to operate and teach the robot without first becoming a robotics engineer.
Choose your path
Run and teach
Apply task knowledge through missions, monitoring, demonstrations and outcome review.
Learn the platform
Build foundations and reach a first verified result in simulation.
Deploy reliably
Configure a supported system for a site, workflow and acceptance target.
Build and own
Hardware, installation, bring-up, calibration and acceptance.
Extend and contribute
Architecture, repositories, contracts and customization guides.
Create a local business
Choose a model, validate demand, launch and join the ecosystem.
Start with the task in front of you
These routes cut across the documentation tree. Use them when you know the outcome you need but not which OpenAMRobot section owns it.
I need to assemble a robot
Prepare the workspace, identify revision-matched parts, assemble one subsystem at a time and verify the result.
I need to start the software
Choose simulation or hardware, install the supported stack and verify the first launch before changing configuration.
I need to create a map
Understand the mapping model, capture the environment and verify that the saved map supports localization.
The robot is not moving
Collect power, control, lifecycle and diagnostic evidence, then isolate the failing layer.
I need to integrate a new sensor
Define the interface, mount and configure the sensor, then verify frames and data quality.
I want to evaluate a customer workflow
Describe the task, environment, constraints and acceptance evidence before proposing automation.
Simulation or hardware?
| Start with simulation when… | Start with hardware when… |
|---|---|
| You are learning navigation, missions or APIs | You must validate mechanics, wiring, sensors or safety |
| You want a reproducible software environment | You are preparing a real deployment or demonstration |
| Hardware is not yet available | You completed the pre-power safety checks |
Know the boundary
Simulation does not validate power, wiring, sensing noise, traction, mechanical tolerances, emergency behavior or site safety.