Stage 4 · Configure
Turn hardware into your robot
Describe the actual platform, environment and operating limits in a reproducible robot profile.
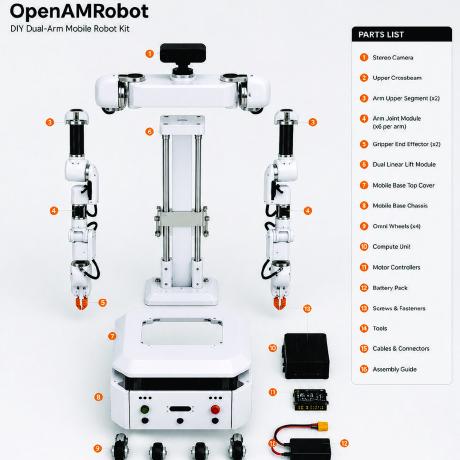
Configuration model
Identity & network
Robot name, site, access point, remote access and security basics.
Hardware inventory
Drive, sensors, compute, lift, arms, grippers and device packages.
Geometry & calibration
URDF, joints, limits, meshes, odometry, IMU, lidar and cameras.
Navigation & docking
Footprint, planners, costmaps, maps, localization and approach tuning.
Manipulation
Planning groups, named poses, grippers, workspace and lift limits.
Safety limits
Speed, zones, keep-out areas, emergency behavior and site constraints.
Designed to mirror the App
The learning sequence follows the planned configuration wizard so the documentation explains what the App will guide and automate.
Next: Train the robot or operate it.