BeginnerBuilder
Planned
Under development
Lift And Vertical Reach
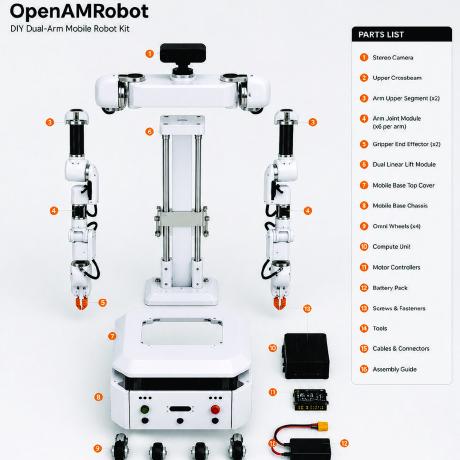
Explain lift and vertical reach in plain language and show how it affects OpenAMRobot.
Documentation framework
This page is part of the approved OpenAMRobot knowledge architecture. It is intentionally published before full content is complete so contributors can fill it consistently. Do not treat unfinished guidance as a validated build or deployment instruction.
What this page should contain
- Audience and outcome: who uses this page and what verified state they should reach.
- Prerequisites: required skills, tools, hardware, software, configuration and safety conditions.
- Concept or procedure: concise explanation followed by ordered, reproducible steps where applicable.
- Verification: observable output, measurement, test or acceptance criterion.
- Troubleshooting: likely failures, evidence to collect and safe recovery actions.
- Next step: one clear continuation in the ownership or development path.
Content template
| Field | To complete |
|---|---|
| For | Name one primary reader: operator, builder, integrator or developer |
| Before you start | List exact prerequisites or state “nothing” |
| When you finish | Describe a measurable outcome |
| Capability status | Stable, beta, experimental, planned, community or partner-supported |
| Applies to | Release, hardware revision and configuration |
| Safety | Hazards, limits, stop conditions and required supervision |
| Verification | What the reader should see, hear, measure or test |
Procedure or explanation
- Establish the starting state.
- Complete one action or concept per subsection.
- Record commands, parameters, screenshots or measurements where useful.
- Verify the result before continuing.
If it did not work
Document symptoms separately from causes. Include diagnostic evidence and a safe rollback or escalation path.
Authoritative external references
Contribution note
Replace this framework with tested project-specific content through the normal contribution workflow. Keep exact parameters and contracts synchronized with the owning repository.