Stage 2 · Build
Build the platform
Move from parts and source files to an inspected, wired and documented robot.
Prepare→Inventory→Assemble→Wire→Install→Inspect
Numbered build path
| Step | Work package | Verification |
|---|---|---|
| 00 | Tools, workspace and safety | Workspace and PPE ready |
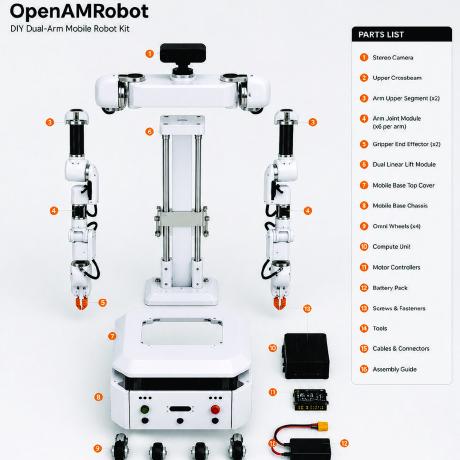
| 01 | Kit contents and BOM | Every required item identified |
| 02 | Chassis | Frame square, fasteners torqued |
| 03 | Drive units | Free rotation and correct mounting |
| 04 | Power and battery | Polarity and protection verified |
| 05 | Compute and wiring | Harness inspected and labelled |
| 06 | Sensors | Mounting, orientation and connections verified |
| 07 | Lift | Travel and limits mechanically checked |
| 08 | Arm mounting | Interface and stability accepted |
| 09 | First power-on | No fault, heat or unexpected motion |
| 10 | Acceptance | Baseline recorded and build documented |
Hardware documentation gate
Build only against the BOM, drawings and release that match each other. Never infer power wiring from a photograph.
Sources: hardware repository · release repository