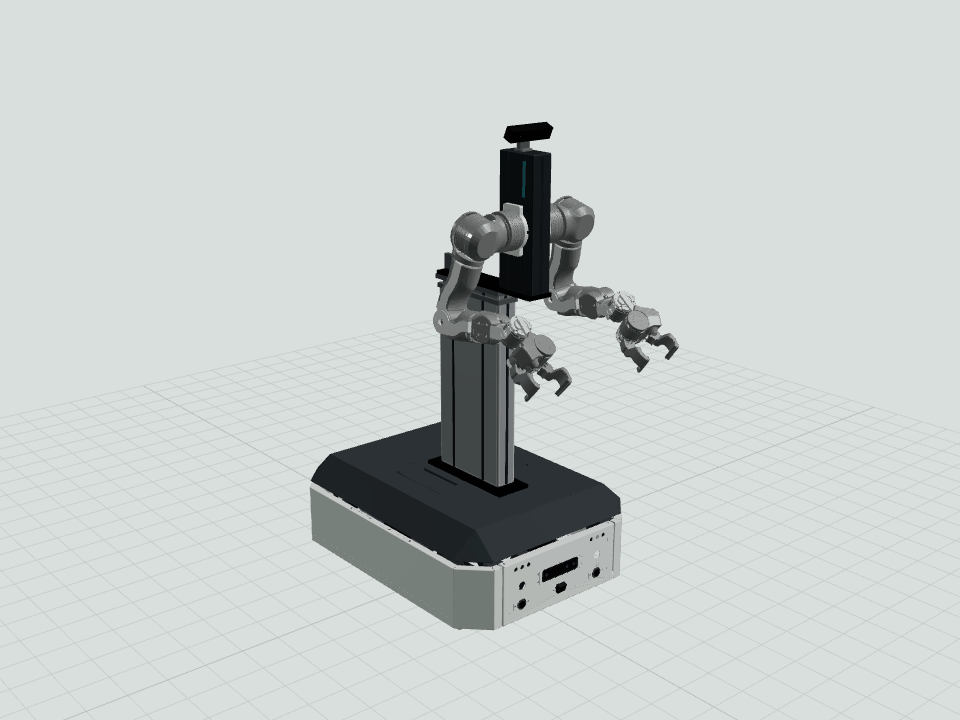
Exploded view: OpenAMRobot 2.0
- What this shows
- The 2.0 robot from the same model as the Robot page: assembled, exploded by subsystem, with the base opened so that its internal components stand above the deck, or as a cutaway with the cover and panels translucent. Every component is numbered, with its BOM Issue 7.11 row and a public source.
- Geometry
- Chassis parts are CAD-derived (CAD v0.2, openamr-platform-hw); base components are simplified envelopes shaped from their datasheet dimensions (the battery as eight LF105 cell boxes inside the cell-group envelope); the lift, plates, arm profile and head camera are primitives from decided dimensions; the arms are the OpenArm 2.0 meshes. Components without a documented position are listed but not drawn.
- Limits
- Visualization only, about ±2 cm. No fasteners, cables or wiring routes are shown; none are documented for 2.0. The battery is a cell-group envelope, provisional, dimensions not released. Positions in the opened base and the exploded views are for reading the parts, not assembly positions.
Tour video
The guided tour above, rendered offline from the same shared model: 1920 x 1080, 30 fps, H.264, no audio, 49.5 s; the vertical cut is 1080 x 1350. Download: 16:9 video (MP4), 4:5 vertical cut (MP4). Visualization only; not an assembly instruction.